Javier Mayorga presented the paper ‘AI-Driven Digital Twin for Real-Time Postural Ergonomics and Fatigue Assessment in Human–Robot Interaction’ at the ICE 2026 conference in Porto.
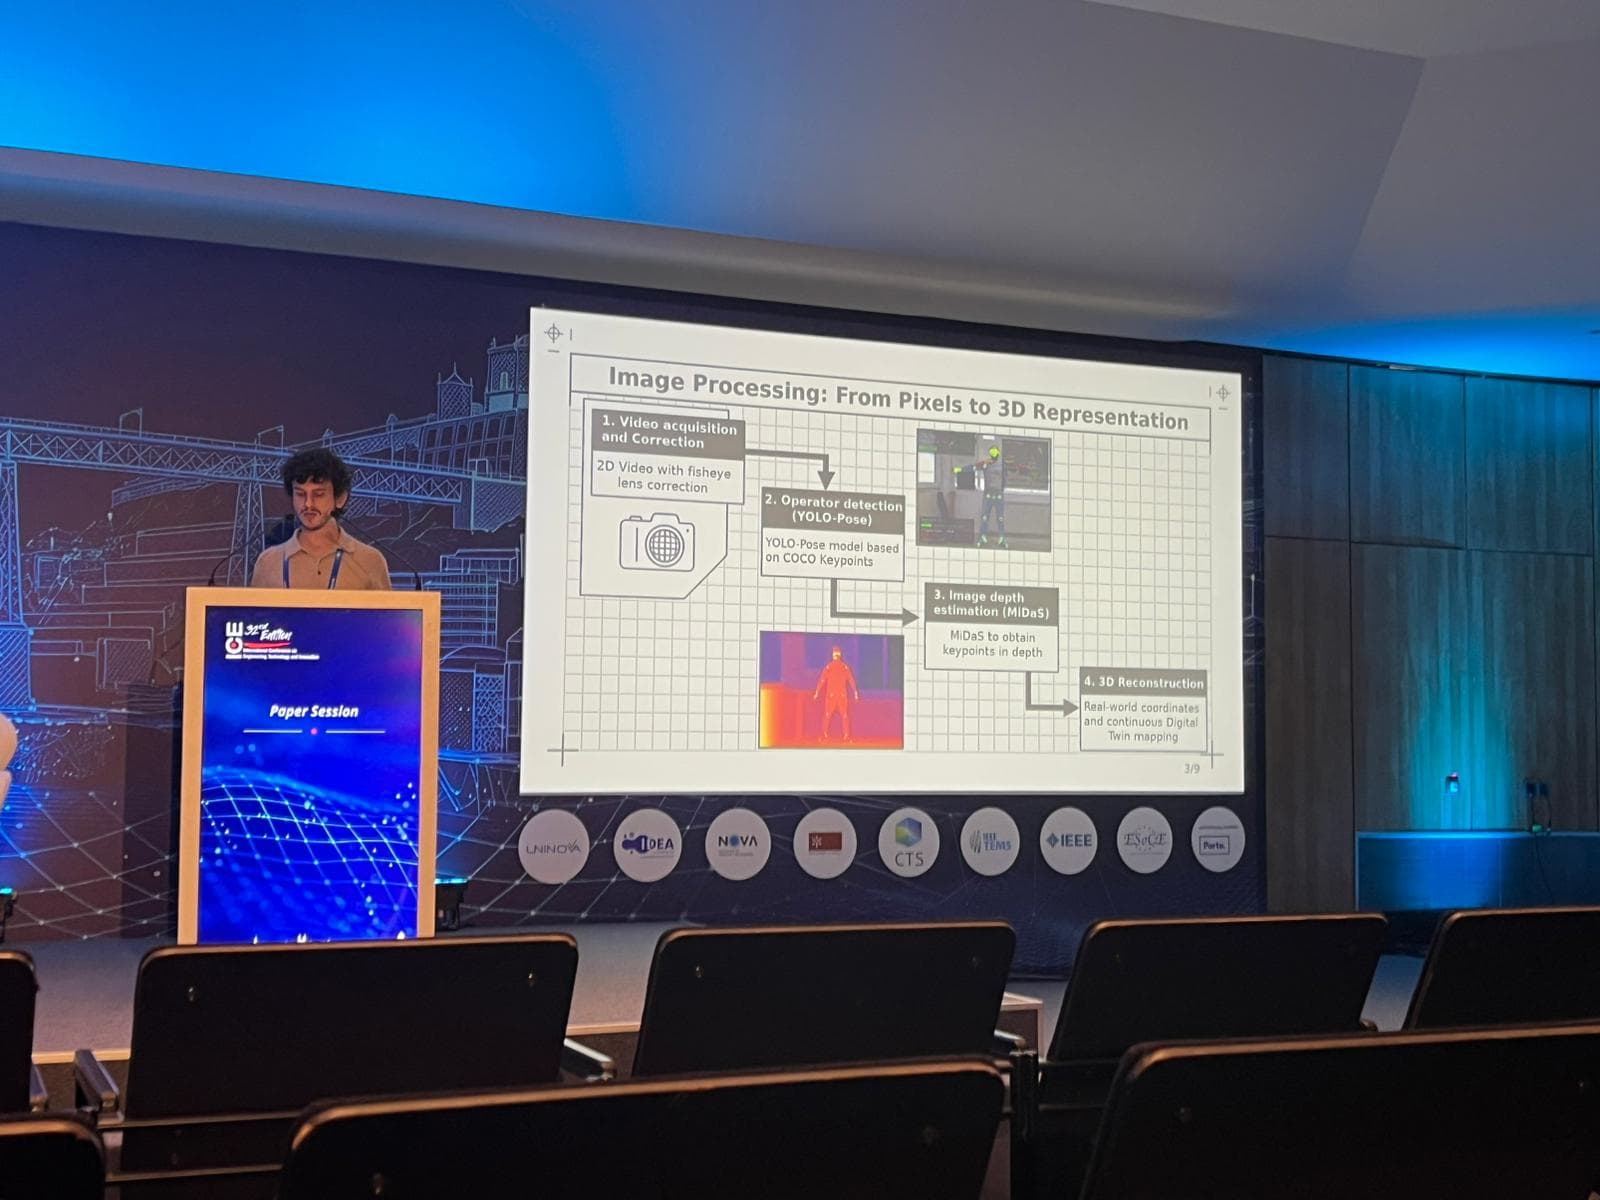
The work introduces a digital twin of the operator built using computer vision and artificial intelligence from monocular video, capable of reconstructing the operator’s 3D posture to assess ergonomics and identify potentially harmful postures.
In addition, it integrates a real-time fatigue estimation module based on exposure to non-neutral postures and repetitive movements. The system provides ergonomic recommendations and visual feedback to help reduce fatigue and promote healthier postures in industrial human–robot interaction environments.
This work has been supported by the European projects ECS4DRES and FORTIS Project.